Documentation
Overview
This section provides build documentation for SPROUT: The Open-Source Soft Robot for Search and Rescue. It covers two subsystems:
- Compute box — onboard computation, power regulation, actuator control, sensing interfaces, networking, and embedded communication hardware. See Bill of Materials, Enclosure, Assembly, and Wiring.
- Vine robot body — the soft, pneumatically-actuated “vine” that everts from the base and is driven by the compute box. See Vine Construction.
Mechanical CAD for both subsystems, plus the robot base, is covered separately under CAD.
The system is designed for:
- field deployment
- modular servicing
- battery-powered operation
- rapid hardware iteration
- reproducible research integration
Documentation map
| Page | Description |
|---|---|
| Bill of Materials | Bill of materials and sourcing |
| Enclosure | Enclosure preparation and mounting layout |
| Assembly | Step-by-step assembly procedure |
| Wiring | Wiring harnesses and connector pinouts |
| Vine Construction | Fabricating the vine robot body |
Compute box
System architecture
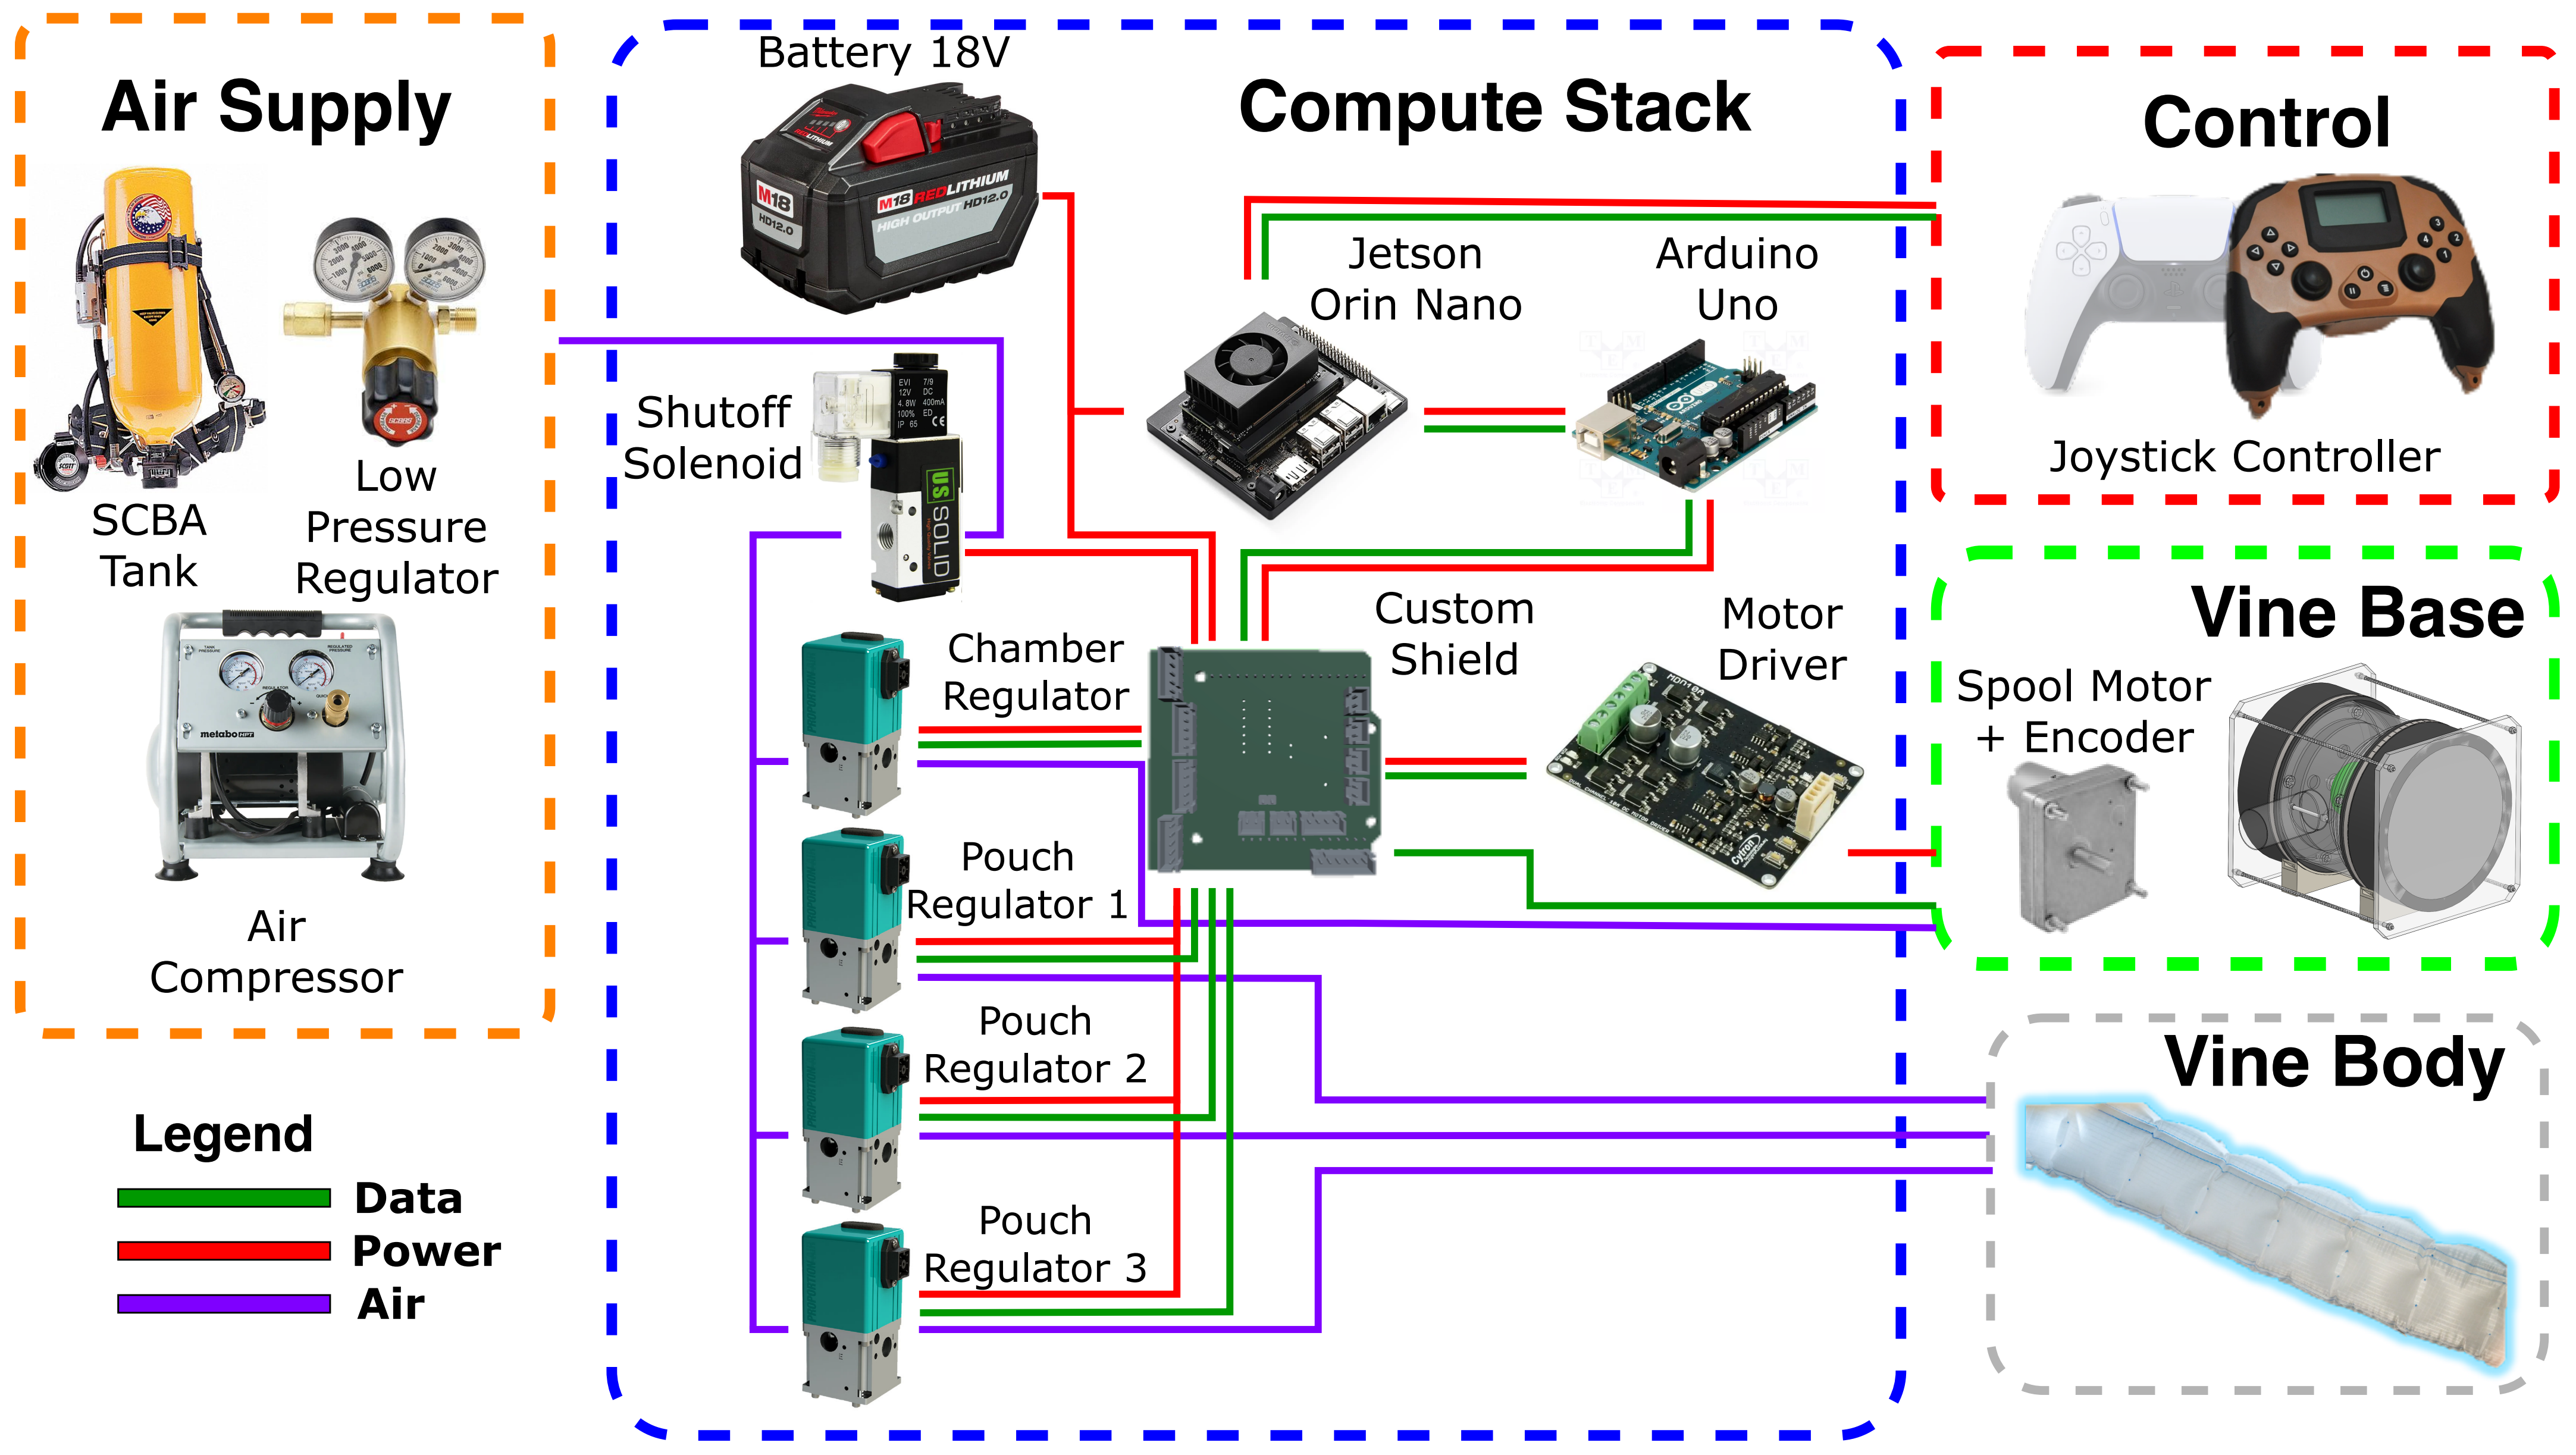
The compute stack coordinates communication between:
- embedded microcontrollers
- motor drivers
- sensing hardware
- pneumatic regulators
- operator interfaces
- power regulation hardware
Major subsystems include:
- Compute Stack
- Control Peripherals
- Vine Base
Compute hardware
| Component | Function |
|---|---|
| NVIDIA Jetson | Main onboard compute |
| Arduino Uno Rev3 | Low-level actuator/sensor interface |
| DC-DC regulators | Power conversion |
| Motor drivers | Actuator control |
Power architecture
The compute box operates from an external DC battery source.
Primary voltage rails:
- 18 V actuator rail
- 15 V auxiliary rail
- 5 V compute rail
All rails are fused independently.
Communication architecture
The system currently uses:
- USB serial communication
- Ethernet
- WiFi
Assembly workflow
Recommended assembly order:
- Mechanical enclosure preparation
- Component mounting
- Power subsystem wiring
- Compute subsystem installation
- Peripheral wiring
- Software flashing/setup
- Validation testing
Safety
Disconnect all power before servicing the compute box.
Verify voltage polarity prior to powering up the system.
Use strain relief for all external cable interfaces.
Vine robot body
The vine body is a soft, pneumatically-actuated structure fabricated from heat-sealable TPU-coated fabric — see Vine Construction for the full fabrication procedure, materials, and inspection/test steps.
Overheating the impulse sealer during fabrication can ruin hours of work in seconds; underheating can produce a body that bursts at low actuation pressures. See Vine Construction → Workspace and equipment preparation.